The Bear Trap is a multirotor quadcopter designed to be a simple and reliable platform to carry out competition mission tasks such as payload drop, waypoint pathing, and target localization.
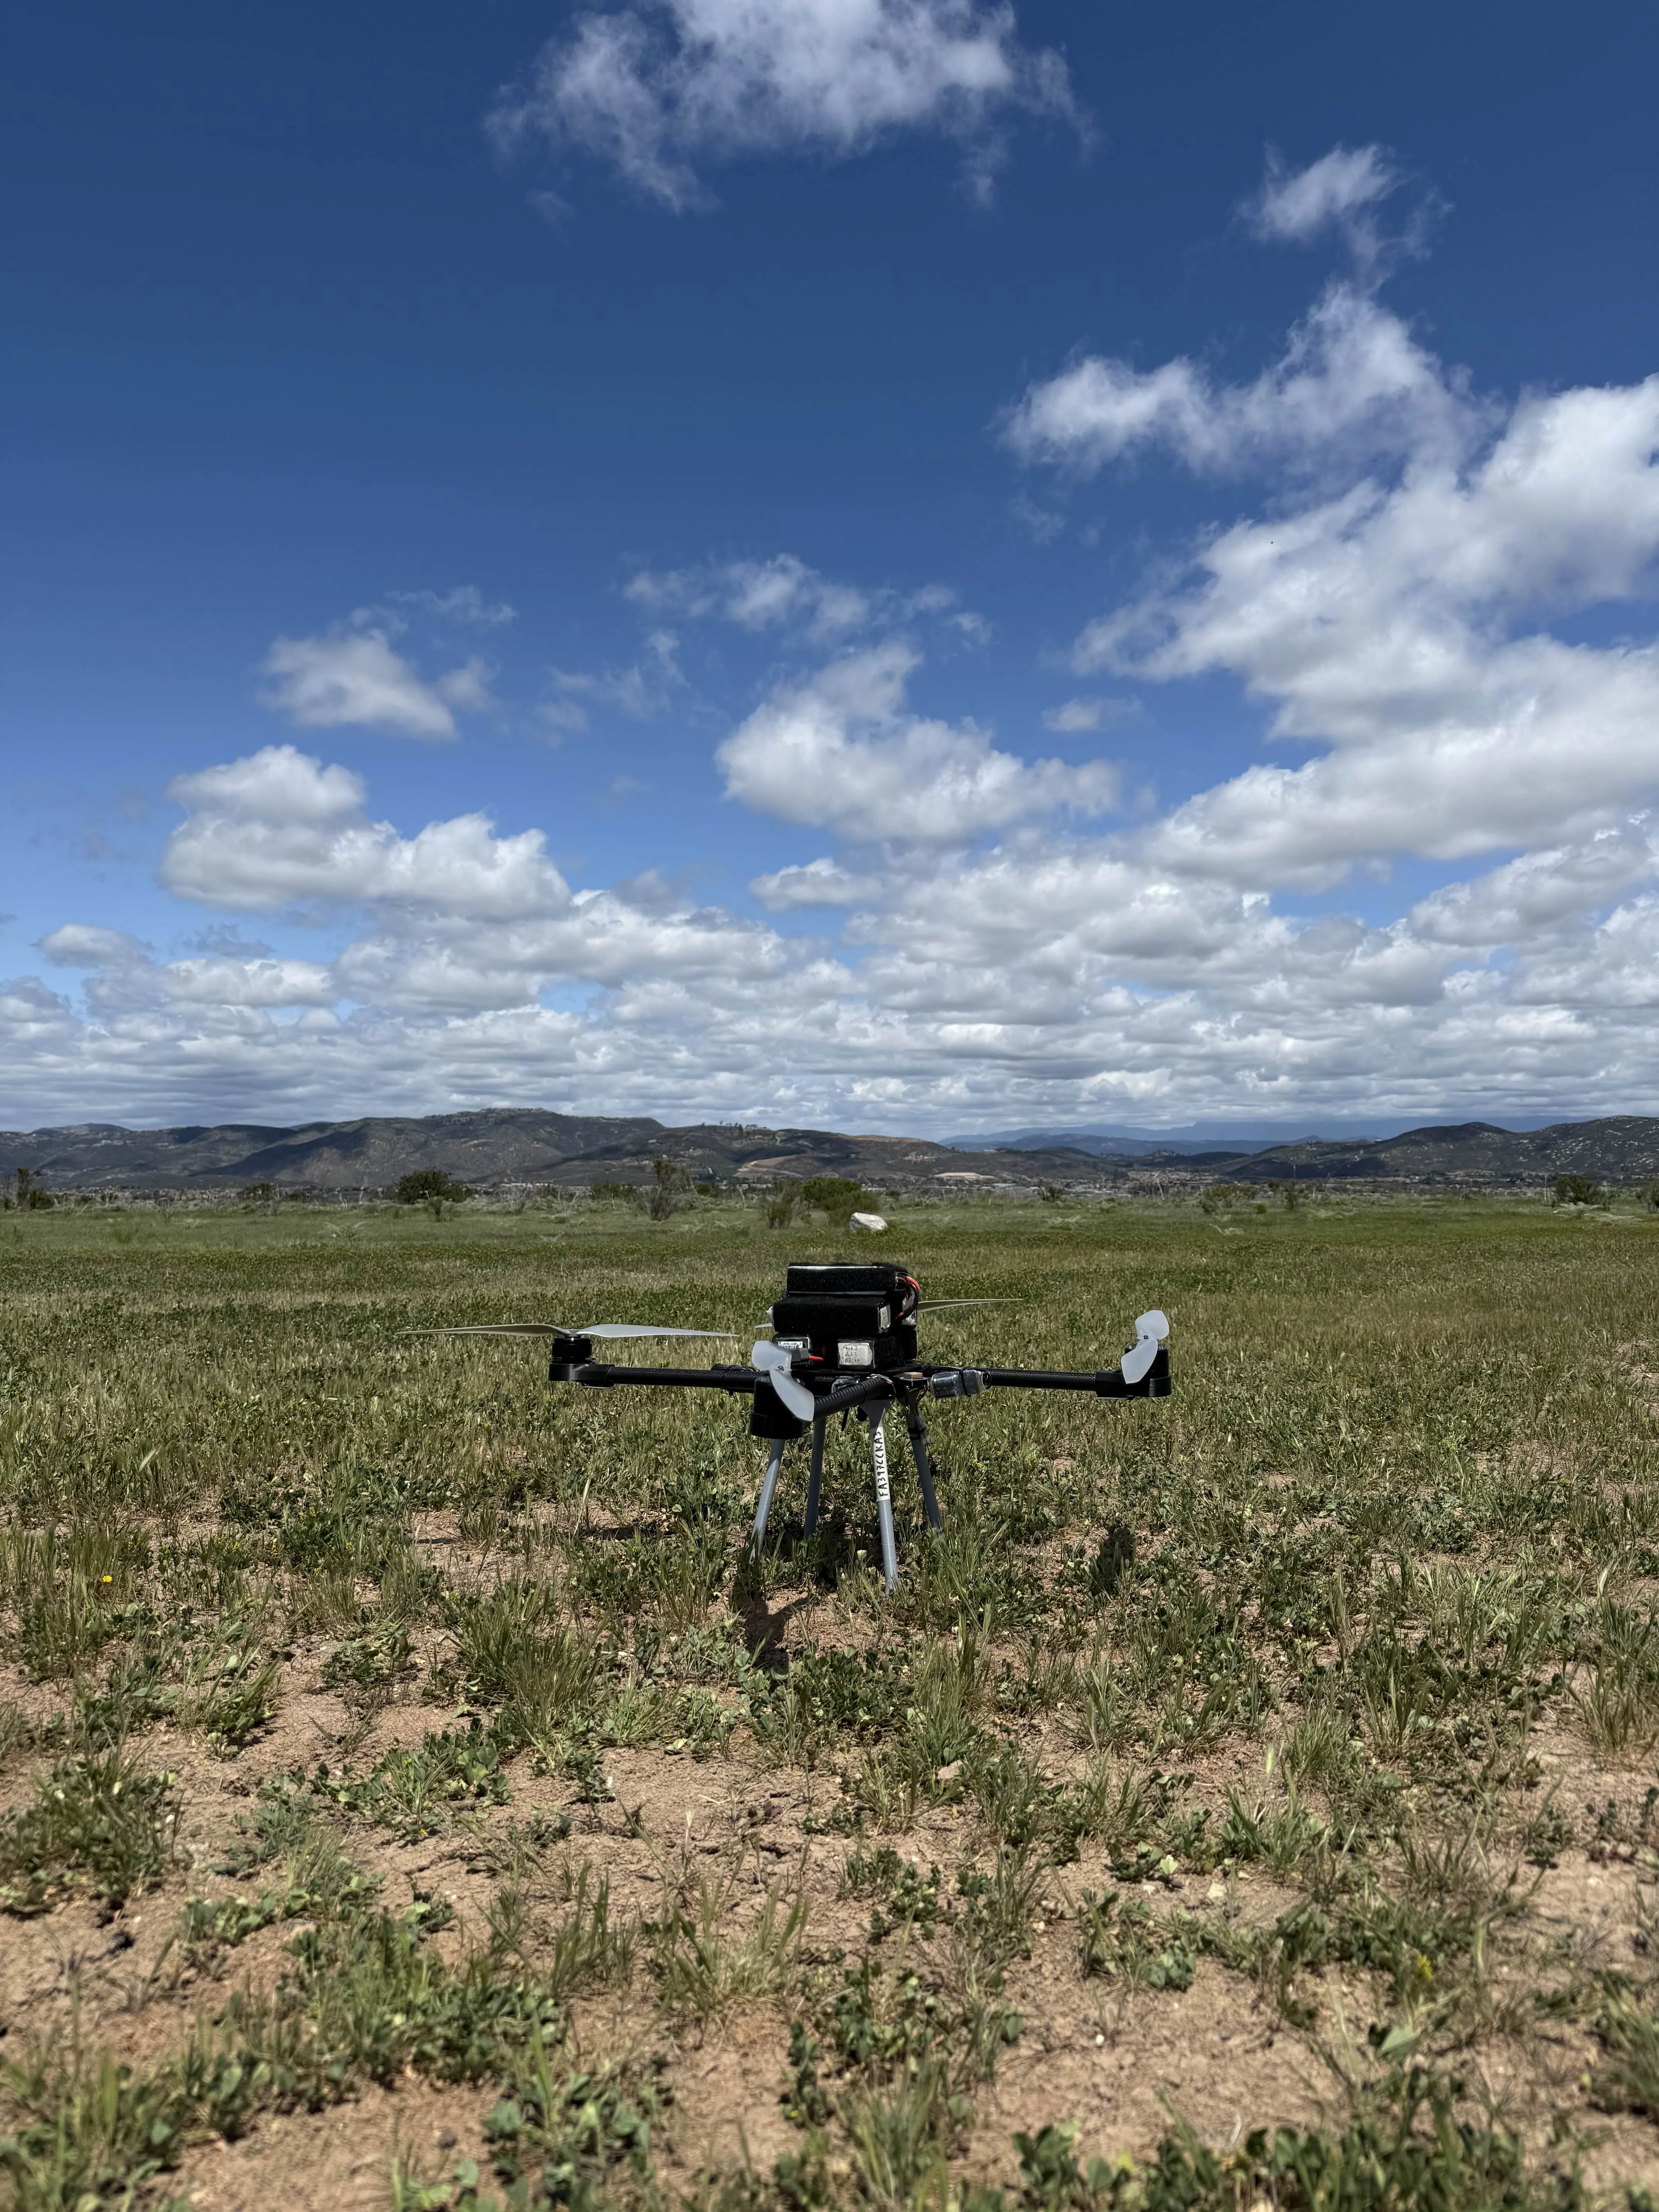
Airframe & Design
- Carbon Fiber Structure: Top and bottom plates made of carbon fiber sandwich motor boom arms in a rigid, lightweight frame.
- Vibration Damping: Stiff structural design minimizes high-frequency motor vibrations to maximize flight controller sensor accuracy.
Powertrain & Efficiency
- High-Thrust Motors: Four 4110 340kv motors generating a combined 10 kg of thrust for a 2.5 thrust-to-weight ratio.
- Battery Configuration: Four 4S 5200 mAh Lithium Polymer batteries in 2s2p setup for long-endurance waypoint flights.
Avionics & Payload Subsystems
- Flight Computer: NVIDIA Jetson Orin Nano handling waypoint pathing, autonomous orchestration, and computer vision.
- Camera & Drop System: Raspberry Pi based camera system, strobe beacon, and custom parachute release mechanism.
Technical Specifications
| Airframe Type | Multirotor Quadcopter |
| Motors | 4110 340kv motors (10 kg thrust) |
| Thrust-to-Weight Ratio | 2.5 TWR |
| Batteries | Four 4s 5200 mAh in 2s2p LiPo setup |
| Companion Computer | NVIDIA Jetson Orin Nano |
| Camera System | Raspberry Pi Camera Server |